I'm a PhD student at the University of California, San Diego, advised by Prof. Michael Yip.
Prior to that, I received my M.S. in Electrical and Computer Engineering from UCSD.
My research lies at the intersection of surgical robotics and computer vision, with a focus on robot learning, state estimation, and 3D reconstruction. I develop algorithms and systems that help robots better perceive and understand surgical scenes, with the goal of making surgery safer and improving patient outcomes. In particular, I am interested in integrating accurate visual perception with robot learning to enable safer and more efficient acquisition of surgical skills. I also explore how general-purpose robots can be integrated into surgical workflows to make high-quality healthcare more accessible to broader populations.
Outside of research, I enjoy piano, films, calisthenics, and outdoor activities.
Publications
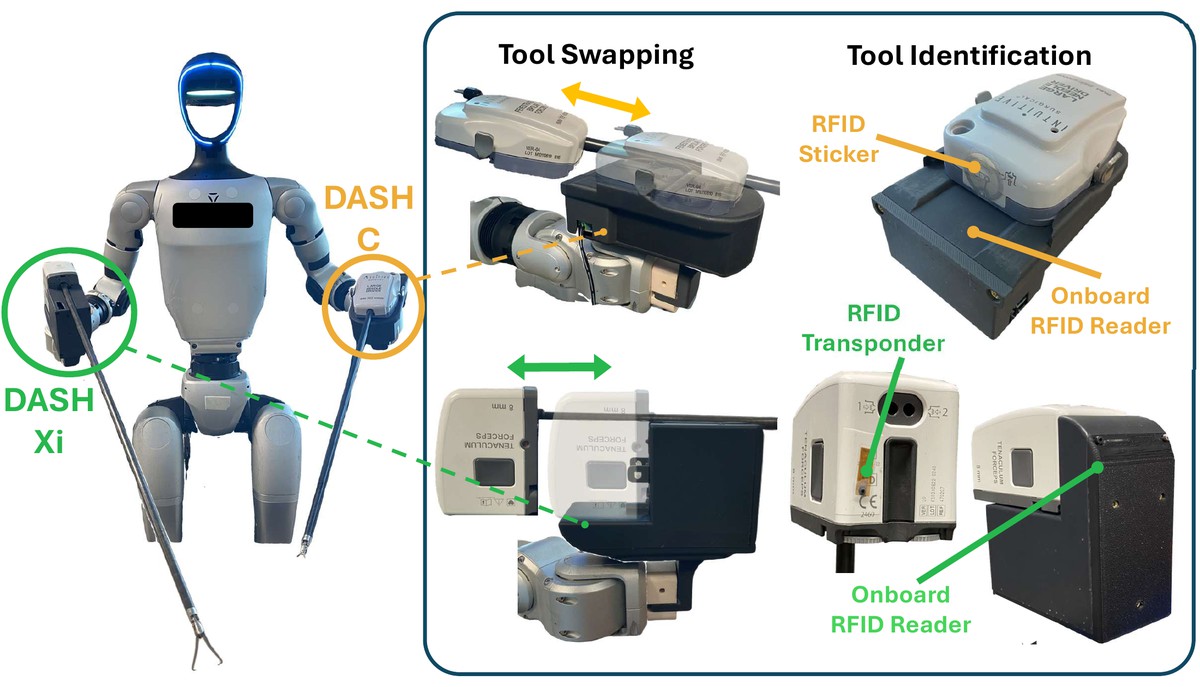
DASH: A da Vinci Adapter for Serial-link and Humanoid Robots as an Accessible Platform for Surgical Robotics Research
Sara Wickenhiser, Junrong Zhou, Zekai Liang, Lizzie Peiros, Shanglei Liu, Michael C Yip
arXiv preprint, 2026
[paper]
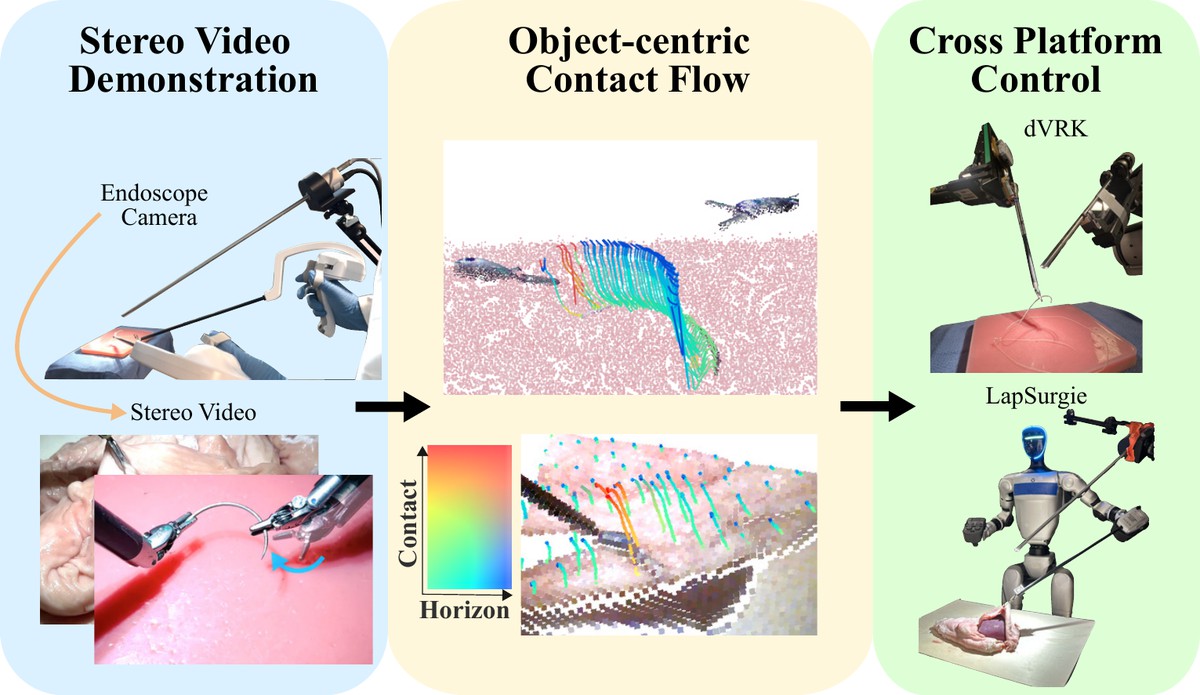
SurgFlow: 3D Object-Centric Contact Flow for Surgical Robot Manipulation
Changwei Chen, Xiao Liang, Yinuo Yang, Nicole Shen, Peihan Zhang, Sara Wickenhiser, Zekai Liang, Soofiyan Atar, Michael Yip
arXiv preprint, 2026
[paper]
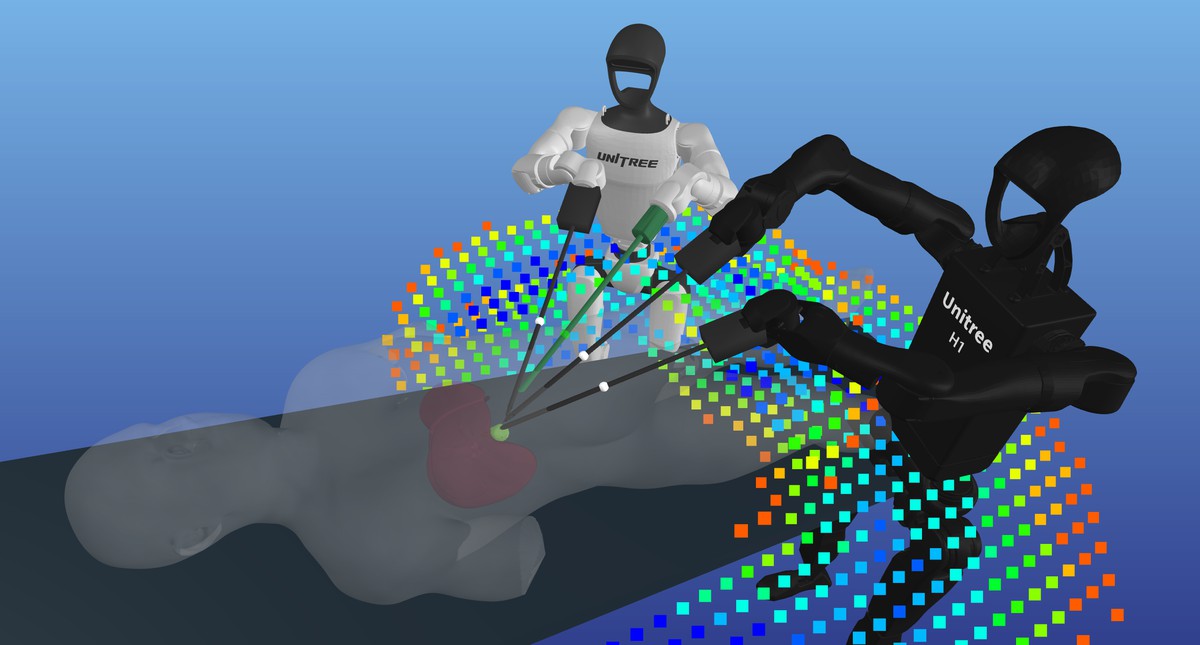
Humanoids for Robot-Assisted Surgery: Bimanual Base Placement and Tool-Mount Optimization via Capability Maps
Peihan Zhang, Zekai Liang, Florian Richter, Nikita Thareja, Ryan Broderick, Shanglei Liu, Michael Yip
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2026
[paper]
In vivo feasibility study of humanoid robots in surgery Zekai Liang, Nikita Thareja, Peihan Zhang, Calvin Joyce, Soofiyan Atar, Florian Richter, Garth Jacobsen, Shanglei Liu, Ryan Broderick, Michael Yip
Nature, 2026
[paper][website][video]
Real-time Rendering-based Surgical Instrument Tracking via Evolutionary Optimization
Hanyang Hu, Zekai Liang, Florian Richter, Michael C Yip
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2026
[paper]
Efficient Surgical Robotic Instrument Pose Reconstruction in Real World Conditions Using Unified Feature Detection Zekai Liang, Kazuya Miyata, Xiao Liang, Florian Richter, Michael C Yip
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2026
[paper]
LapSurgie: Humanoid Robots Performing Surgery via Teleoperated Handheld Laparoscopy Zekai Liang, Xiao Liang, Soofiyan Atar, Sreyan Das, Zoe Chiu, Peihan Zhang, Calvin Joyce, Florian Richter, Shanglei Liu, Michael C Yip
IEEE International Conference on Robotics and Automation (ICRA), 2026
[paper]
BASED: Bundle-Adjusting Surgical Endoscopic Dynamic Video Reconstruction using Neural Radiance Fields
Shreya Saha, Zekai Liang, Shan Lin, Jingpei Lu, Michael Yip, Sainan Liu
IEEE/CVF Winter Conference on Applications of Computer Vision (WACV), 2025
[paper]
Differentiable rendering-based pose estimation for surgical robotic instruments Zekai Liang, Zih-Yun Chiu, Florian Richter, Michael C Yip
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2025
[paper]
CtRNet-X: Camera-to-Robot Pose Estimation in Real-world Conditions Using a Single Camera
Jingpei Lu*, Zekai Liang*, Tristin Xie, Florian Richter, Shan Lin, Sainan Liu, Michael C Yip
IEEE International Conference on Robotics and Automation (ICRA), 2025
[paper]